
How to Build a Biped Robot: Design to First Steps (2026)
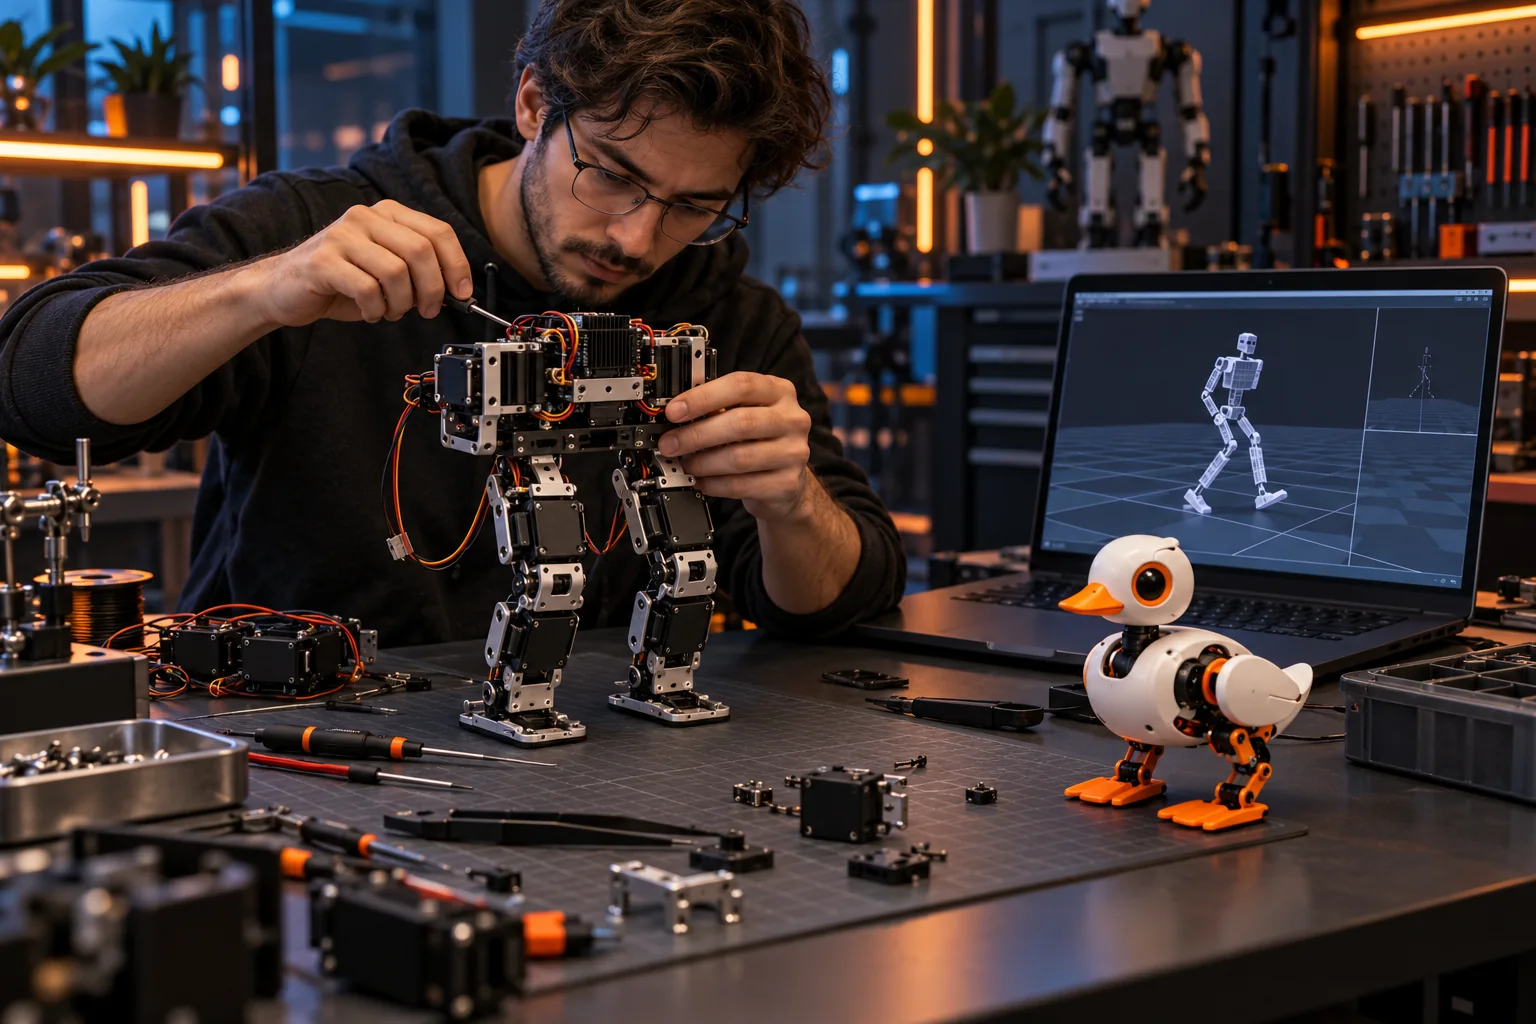
Build a biped robot by reducing uncertainty in order: define the task, size the joints, design a serviceable frame, make the electronics match, build a simulation model, calibrate every joint and test in stages. Starting with a finished-looking shell or a reinforcement-learning run hides the mechanical and integration errors that will dominate the first hardware test.
This guide is the execution path for a small research or maker biped. It uses Microduck and Open Duck Mini v2 as documented examples, but it does not assume either robot's hardware files are open.
What should you decide before building a biped robot?
Decide the task, payload, operating surface and safety boundary before choosing parts. “A walking robot” is not a specification because standing, walking, turning and recovery place different demands on joint range, torque and control.
Define:
- the task and success measure;
- required height and weight;
- degrees of freedom;
- walking speed and terrain;
- sensors and onboard compute;
- available power and run time;
- control rate and software stack;
- acceptable fall behaviour and supervision;
- budget, tools and build time.
A small biped that walks on a desk is a different engineering problem from a larger robot that must recover from pushes or carry a payload. Document the assumptions before they become hidden inside CAD.
How many degrees of freedom does a biped need?
A simple planar walker can work with hip and knee pitch joints, while a practical small biped usually adds hip roll and ankle motion for lateral balance and turning. More joints increase control authority and also add mass, backlash, wiring and calibration work.
Use the movement envelope, not a target joint count, to decide. For every candidate joint, ask whether the task fails without it and whether the actuator mass is justified.
Microduck uses 15 motors across its legs, body and expressive features. Its seven shipped behaviours depend on the combined mechanism and sensing stack, not on a generic biped formula. Open Duck Mini v2 is another reference point with published CAD and build resources.
How do you size biped robot actuators?
Calculate the torque each joint needs through its worst load path, then add margin for acceleration, impacts, friction and model error. Do not choose an actuator by its advertised stall torque alone.
Check:
- continuous and peak torque;
- speed at the required joint range;
- voltage and current limits;
- gearbox ratio and backlash;
- holding behaviour and heat;
- position-feedback resolution;
- communication protocol and update rate;
- replacement availability and cost.
Simulation helps compare candidate mechanisms, but actuator behaviour must eventually be measured. Open Duck's documentation includes actuator identification, while Microduck's software architecture explains the 50 Hz motor-control loop and safety ownership.
How do you design the frame and joints?
Design for alignment, service access and controlled compliance. The frame must carry the reaction torque without making bearing misalignment or fastener crush more likely.
Priorities:
- Keep mass close to the body and away from the feet.
- Give every joint a mechanical datum and repeatable assembly reference.
- Make bearings and shafts easy to inspect.
- Leave room for cable travel through the full range.
- Use replaceable feet and bumpers around the first test area.
- Design access to motor IDs and firmware ports.
- Separate cosmetic shells from load-bearing structure.
If you print the frame, read 3D printed biped robot before slicing. Layer direction and joint tolerance can turn a correct model into a robot that binds.
How should power and electronics be arranged?
Put power conversion, emergency interruption, communication and actuator protection on paths you can test independently. A robot that can walk poorly is still unsafe if a short or runaway joint cannot be isolated.
The electrical build should include:
- a correctly sized battery and charger;
- fusing or current protection appropriate to the design;
- one emergency power cut that is reachable during testing;
- regulator margins for compute and sensors;
- actuator bus termination and strain relief;
- stable logic and sensor power;
- accessible debug and recovery interfaces;
- measured current and temperature during bench tests.
Do not expose battery voltage or other unsafe wiring on the public-facing robot surface. Follow the battery, charger and actuator specifications from their manufacturers.
How does simulation fit into the build?
Build the simulation model alongside the hardware so joint axes, masses, collision geometry and actuator limits stay synchronized. Simulation is a development tool, not a replacement for commissioning the physical robot.
At minimum, verify:
- every joint maps to the correct axis and index;
- positive command directions match hardware;
- joint limits match the CAD range;
- link masses and centres of mass are plausible;
- feet and contact geometry match the test surface;
- actuator delay and current limits are represented;
- the controller can export in the runtime's format.
Microduck's simulator guide and training path show the software side. Open Duck's sim-to-real notes are a second project-level reference.
How do you calibrate the robot before walking?
Calibrate one joint at a time with the robot supported and the propulsive range disabled. Confirm identity, direction, zero, limits and safety stop before running a standing controller.
The first commissioning order is:
- Read every joint ID and firmware version.
- Establish mechanical zero at the documented pose.
- Move each joint slowly through its safe range.
- Check feedback direction and resolution.
- Measure supply sag and actuator temperature.
- Power the standing controller on a stand.
- Test a current-limited step with an operator ready to stop it.
Do not begin with a learned walking policy. A policy expects a calibrated action contract, and small joint errors can become large whole-body failures.
What should the first hardware tests look like?
Test in stages: jointless electronics, individual joints, supported standing, short standing, weight shift, one or two steps and finally supervised floor runs. Keep every stage bounded and repeatable.
A useful first test records more than “it walked”. Record falls, safety stops, current, joint tracking, foot slip, intervention and the exact controller configuration.
The robot policy evaluation guide defines a structured test suite. Keep a firmware and model version for every attempt so a successful step can be reproduced.
How much does it cost to build a biped robot?
Budget the complete system: mechanism, actuators, electronics, sensors, battery, tools, spares, failed parts, shipping, tax and engineering time. A low parts total can obscure the most expensive input, which is usually integration.
Use these three budgets:
| Budget | Include |
|---|---|
| Prototype BOM | Parts and one replacement for high-risk components |
| Build budget | Tools, printing, failed parts, fasteners, shipping and tax |
| Operating budget | Spares, additional batteries, maintenance and experiment time |
For published references, inspect the Open Duck Mini v2 build cost and the Microduck cost guide. One is a community project target; the other is an assembled product price.
How do you keep a custom biped safe?
Keep the robot on a stand, limit current and speed, protect the floor and keep the power cut within reach. Never test a new walking policy near people, stairs, desks or a hard drop until the controller and robot have passed slower checks.
Safety improves when the software has clear ownership of motor commands, limits and emergency stopping. Microduck's architecture keeps motor control in one dedicated daemon; a custom robot should define an equally explicit boundary.
How to build a biped robot FAQ
Can a beginner build a biped robot? Yes, with a documented project and realistic scope. Begin with an existing open design or assembled platform before designing every subsystem.
How many motors does a walking biped need? A minimal planar walker needs fewer joints than a practical omnidirectional robot. Add degrees of freedom only when the task requires them.
What is harder, hardware or software? Integration is harder than either in isolation. Joint mapping, calibration and mechanical behaviour must match the simulator and controller.
Can 3D-printed parts support a biped? Yes, when the design is structurally appropriate and follows the project's print and assembly guide. Printed load paths need careful testing.
Can reinforcement learning make a weak mechanism walk? RL can improve robustness, but it cannot reliably compensate for slipping horns, binding bearings or missing torque.
What should the first controller do? Calibrate the joints and hold a supported standing pose. Walking comes after identity, limits and safety checks pass.
Key takeaways
- Define the task before choosing degrees of freedom or actuators.
- Size joints from load-path calculations, not one torque number.
- Design for alignment, service and an accessible emergency stop.
- Keep simulation axes, masses and limits synchronized with hardware.
- Commission one joint at a time and test walking in stages.
- Budget integration, tools and spares as part of the robot.
Where to go next
- Open source biped robot - decide how much you want to own
- 3D printed biped robot - printable mechanisms and files
- DIY biped robot kit - build, assembled and ready-made routes
- Microduck specs - an assembled 15-motor biped reference
- Microduck simulator - start the software side
- How to train Microduck - the policy workflow